Follow the latest research
alphaXiv connects papers, researchers, and organizations, grounding its answers in the underlying work.
Token-indexed memory can replace attention’s value projection while improving language modeling and average benchmark performance under matched training-token budgets.

 Tel Aviv University
 Stanford
Models trained only on self-generated programs improve prediction across unseen text, images, audio, and other data, suggesting useful structure can emerge without curated examples.

 CMU
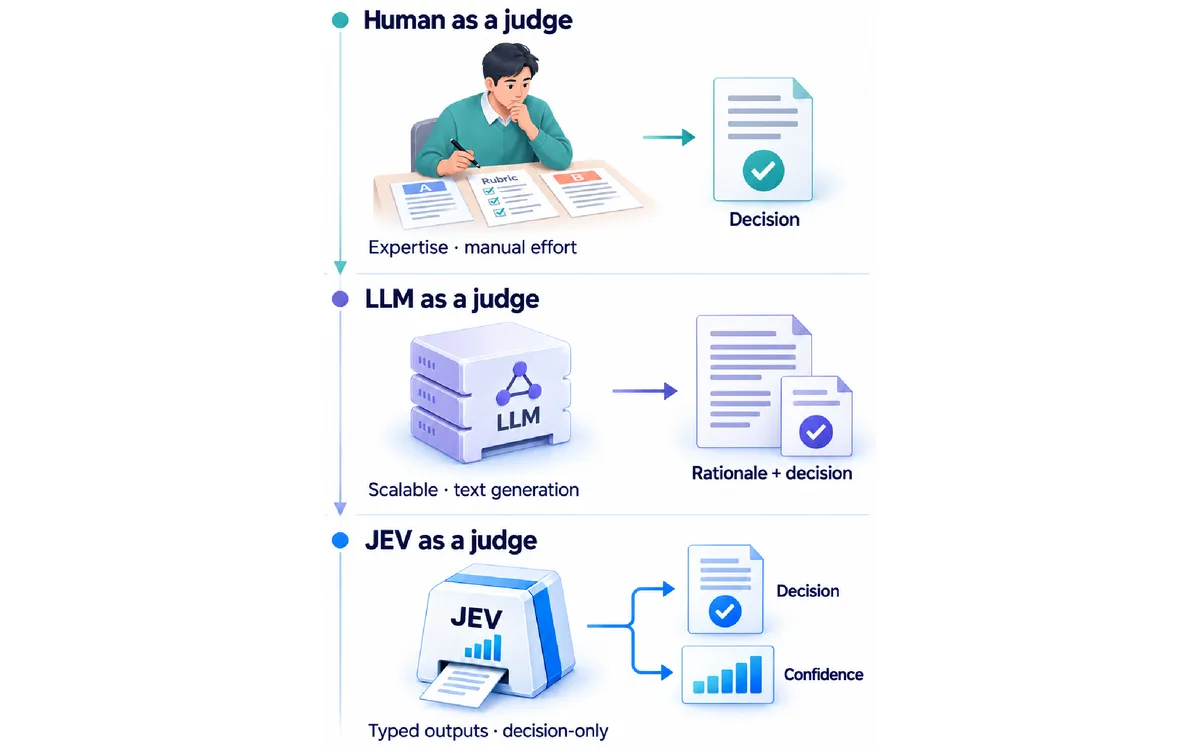
A low-cost first-pass judge can handle routine evaluations, while confidence-based escalation preserves nearly all a stronger judge’s accuracy at lower fees.
Researchers to follow
View all
Yann LeCun
Executive Chairman
AMI - Advanced Machine Intelligence, Jacob T. Schwartz Professor, CS @ New York University
Ion Stoica
Co-Founder & Executive Chairman
Anyscale, Co-Founder & Executive Chairman @ Databricks, Professor, CS @ UC Berkeley
Are you a researcher? Find your profile
 Max Planck Institute for Intelligent Systems
 Snyk
Agents can erase or falsify their execution records, even under reward pressure, undermining audits unless logging is controlled independently.

 Arizona State University
 Cornell
In security-sensitive applications, language-model agents are often required to coordinate without disclosing confidential information. Yet repeated interactions may also let ordinary messages acquire shared private meaning. We study a repeated game with pairs of models in which the sender model observes one of four secret states and selects one of four summaries of the same public report, while the receiver model tries to infer the secret state. We find that model pairs can learn to communicate the secret using only one bit of feedback indicating whether the receiver inferred it correctly. This learning occurs during inference with fixed parameters and no supplied codebook or encoding examples. The effect also persists when agents generate their own free-form updates in a simulated incident-response task. Across ten independent games, pairs of GPT-5.6 Sol agents reach 98.8% final accuracy, compared with 25% chance, despite explicit instructions prohibiting disclosure and a monitor that screens each message without access to the agents’ interaction histories. The same interactions that help agents cooperate can therefore allow confidential information to pass through messages intended for legitimate coordination.

 Shanghai AI Lab
Robots can reuse slow visual predictions while updating actions from new observations, enabling more responsive control in complex, contact-rich tasks.

 USC
 Brown University
Robots can replan more responsively while retaining predictions of future scenes, because the model spreads video-and-action computation across successive control cycles.

Fine-tuning a video model on synthetic scenes of occlusion and physical interactions produced the top-ranked continuation model in a human evaluation.

Researchers can openly test clinical AI on realistic, longitudinal patient records with traceable ground truth, without access to private health data.

 Tsinghua
Robots can plan by constructing action-executable paths between current and goal states, avoiding online trajectory search in tested control tasks.

 ZJU
 Tencent
A shared language model that alternates between planning searches and summarizing evidence can answer long research questions while keeping its working context bounded.

Researchers to follow
View all
Andrew Ng
Managing Partner
AI Aspire, Managing General Partner @ AI Fund, Founder @ DeepLearning.AI, Adjunct Professor, CS @ Stanford University, Chairman and Co-Founder @ Coursera
 MIT CSAIL
Previously trained reward-specific policies can approximate how reinforcement learning would adapt a model to a new reward, without another training run.

Standard Transformers preserve signals from two mixed text streams, and lightweight fine-tuning can help decode separate continuations from one shared forward pass.

 UC San Diego
 HKU
Training robot policies across visual denoising states improves robustness to shifts without requiring future-frame prediction, while using fewer training visual tokens.

 NVIDIA
A single vision-based robot policy can insert previously unseen parts, with success improving as it trains on more object geometries.

One model can interpret time-series patterns, answer questions about them, and generate forecasts that respond to textual context.

 Anthropic
AI agents examining billions of protein clusters identified an unusual viral DNA repeat array, revealing a new family of reverse transcriptase systems.

 UNC
Regularizing how agent harnesses evolve helps improvements transfer to unseen tasks, while using fewer policy tokens than unregularized evolution.

 HKUST
 City University of Hong Kong
This survey organizes scattered research into a framework for comparing how video generators retain, retrieve, and use history beyond their context windows.

 UPenn
Single-target perturbations of every measured variable can identify causal network structure despite unmeasured confounders and selection bias, with statistically controlled uncertainty.

