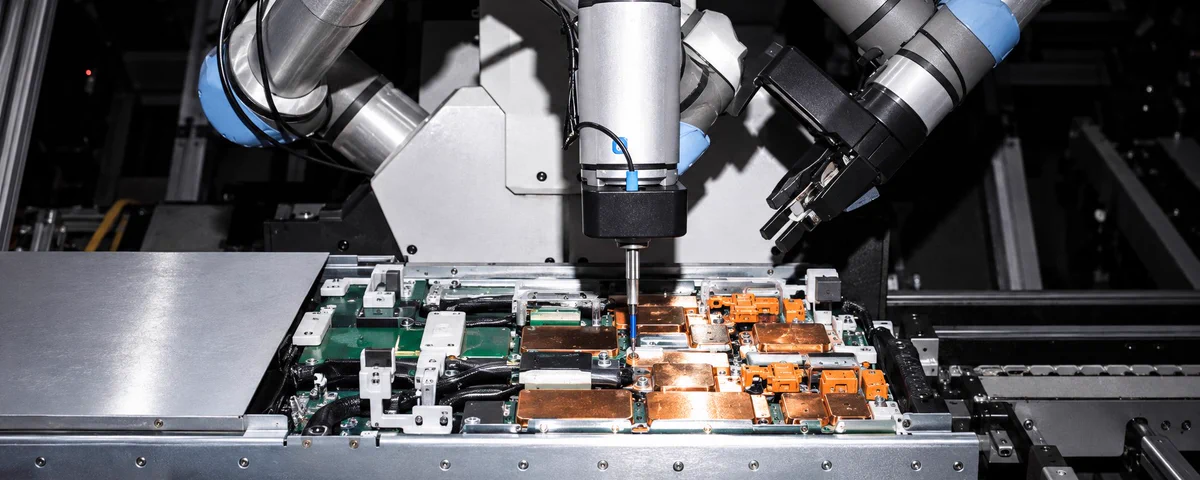
@SkildAI's new S1 robot foundation model helps robots learn previously unseen tasks from a single video demonstration. 🤖
See how NVIDIA technology supports S1 from training and simulation to real-world deployment.
Learn more ➡️ nvda.ws/4r29k7E
We just hit 100M ARR, 10 months after our first deployment.
One of the fastest growing physical companies in human history.
Deeply grateful to our team and partners for making this achievement possible. We're just getting started.
We just hit 100M ARR within 10 months of starting deployments.
We are in factory lines. On construction sites. In kitchens. In data centers.
Cleaning. Welding. Building. Cooking.
Deploying.
If S1 makes a mistake, it tries again.
For example, the input video prompt here attached the wheel just once. During deployment the wheel didn't align properly, so S1 re-aligned it.
By watching the prompt, S1 understands the goal and improvises to get there:
"Does S1 exhibit physical prompt steerability: different prompts induce distinct behavior in the same environment?"
Yes! Watch S1 follow 4 different video prompt recipes in the same kitchen.
The first one is something far out of distribution -- "putting a plate in a toaster".
Introducing S1, our new foundation model that learns from one example.
It can be taught 10-minute long tasks that it has never seen before, from one video prompt without any fine-tuning.
Watch S1 operate in real-time via in-context learning: