𝗔𝗳𝘁𝗲𝗿 𝟭𝟬+ 𝘆𝗲𝗮𝗿𝘀 𝗶𝗻 𝗿𝗼𝗯𝗼𝘁 𝗹𝗲𝗮𝗿𝗻𝗶𝗻𝗴, from my PhD at Imperial to Berkeley to building the Dyson Robot Learning Lab, one frustration kept hitting me:
𝗪𝗵𝘆 𝗱𝗼 𝗜 𝗵𝗮𝘃𝗲 𝘁𝗼 𝗿𝗲𝗯𝘂𝗶𝗹𝗱 𝘁𝗵𝗲 𝘀𝗮𝗺𝗲 𝗶𝗻𝗳𝗿𝗮𝘀𝘁𝗿𝘂𝗰𝘁𝘂𝗿𝗲 𝗼𝘃𝗲𝗿 𝗮𝗻𝗱
Wrist cameras give robots great close-ups, but they’re stuck to the hand. FoveaVLA asks whether the policy can just choose where to look instead.
@bingao_chen, Karen Liu, Guy Tevet and the team at @Stanford and @Princeton built it on π0.5. With every action chunk, the model also
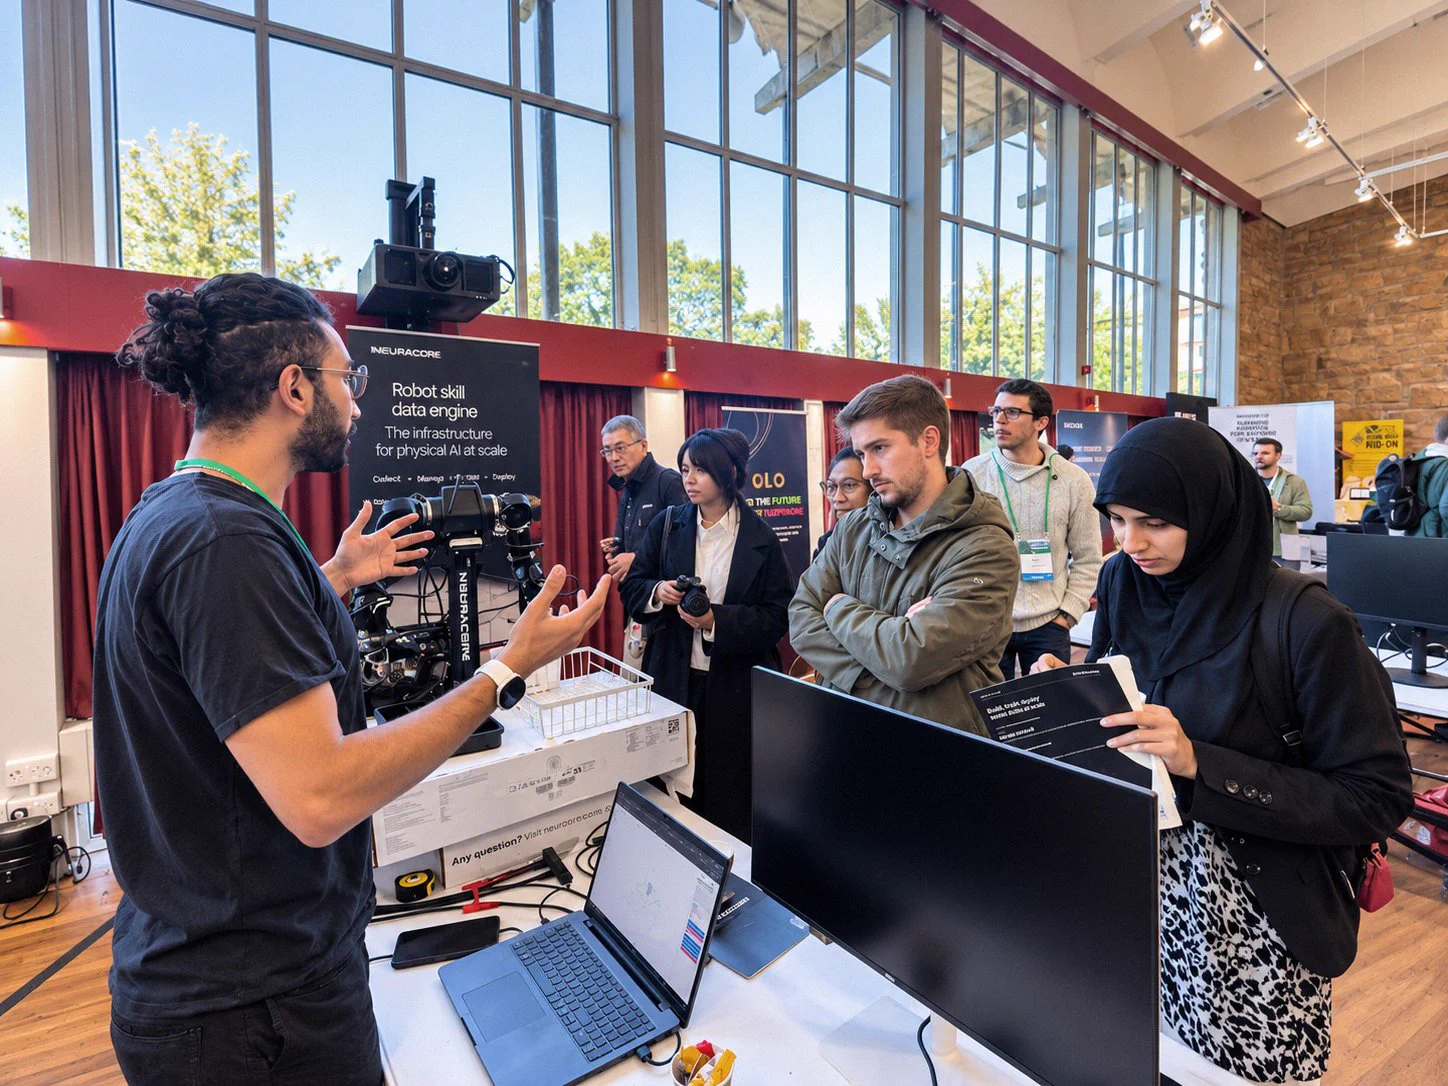
The @Neuracore_AI team will be running live demos at @ABBRobotics upcoming event on the 2nd of December.
Come and join us and see what’s ready to deploy on the robots you already run.
Will you be at @ABBRobotics PoWa of Collaboration event in Milton Keynes on 2 December?
The Neuracore team will be there. Come and say hello.
We’ll be talking about how teams go from collecting demonstrations on the cobots they already run to deploying trained skills. Neuracore
Good data starts with good visibility.
Trace Viewer makes it easier to understand what's happening during data collection, spot issues early and know exactly what you're feeding into training.
Another step towards making robot learning workflows more reliable.
New in Neuracore: Trace Viewer shows every time you log data and highlights issues in your data collection pipeline. Review your raw data before synchronisation, giving you full visibility into what's being collected and allowing you to catch problems early. Know exactly what's
𝗘𝘃𝗲𝗿𝘆 𝗳𝗲𝘄 𝗺𝗼𝗻𝘁𝗵𝘀 𝘀𝗼𝗺𝗲𝗼𝗻𝗲 𝗽𝗼𝘀𝘁𝘀 𝘁𝗵𝗮𝘁 𝗨𝗞 𝗿𝗼𝗯𝗼𝘁𝗶𝗰𝘀 𝘁𝗮𝗹𝗲𝗻𝘁 𝗶𝘀 𝗹𝗲𝗮𝘃𝗶𝗻𝗴 𝗳𝗼𝗿 𝘁𝗵𝗲 𝗩𝗮𝗹𝗹𝗲𝘆.
I did my postdoc at Berkeley and came back to London. Turns out I’m not the only one.
The @Neuracore_AI team just spent three