We split the task in two:
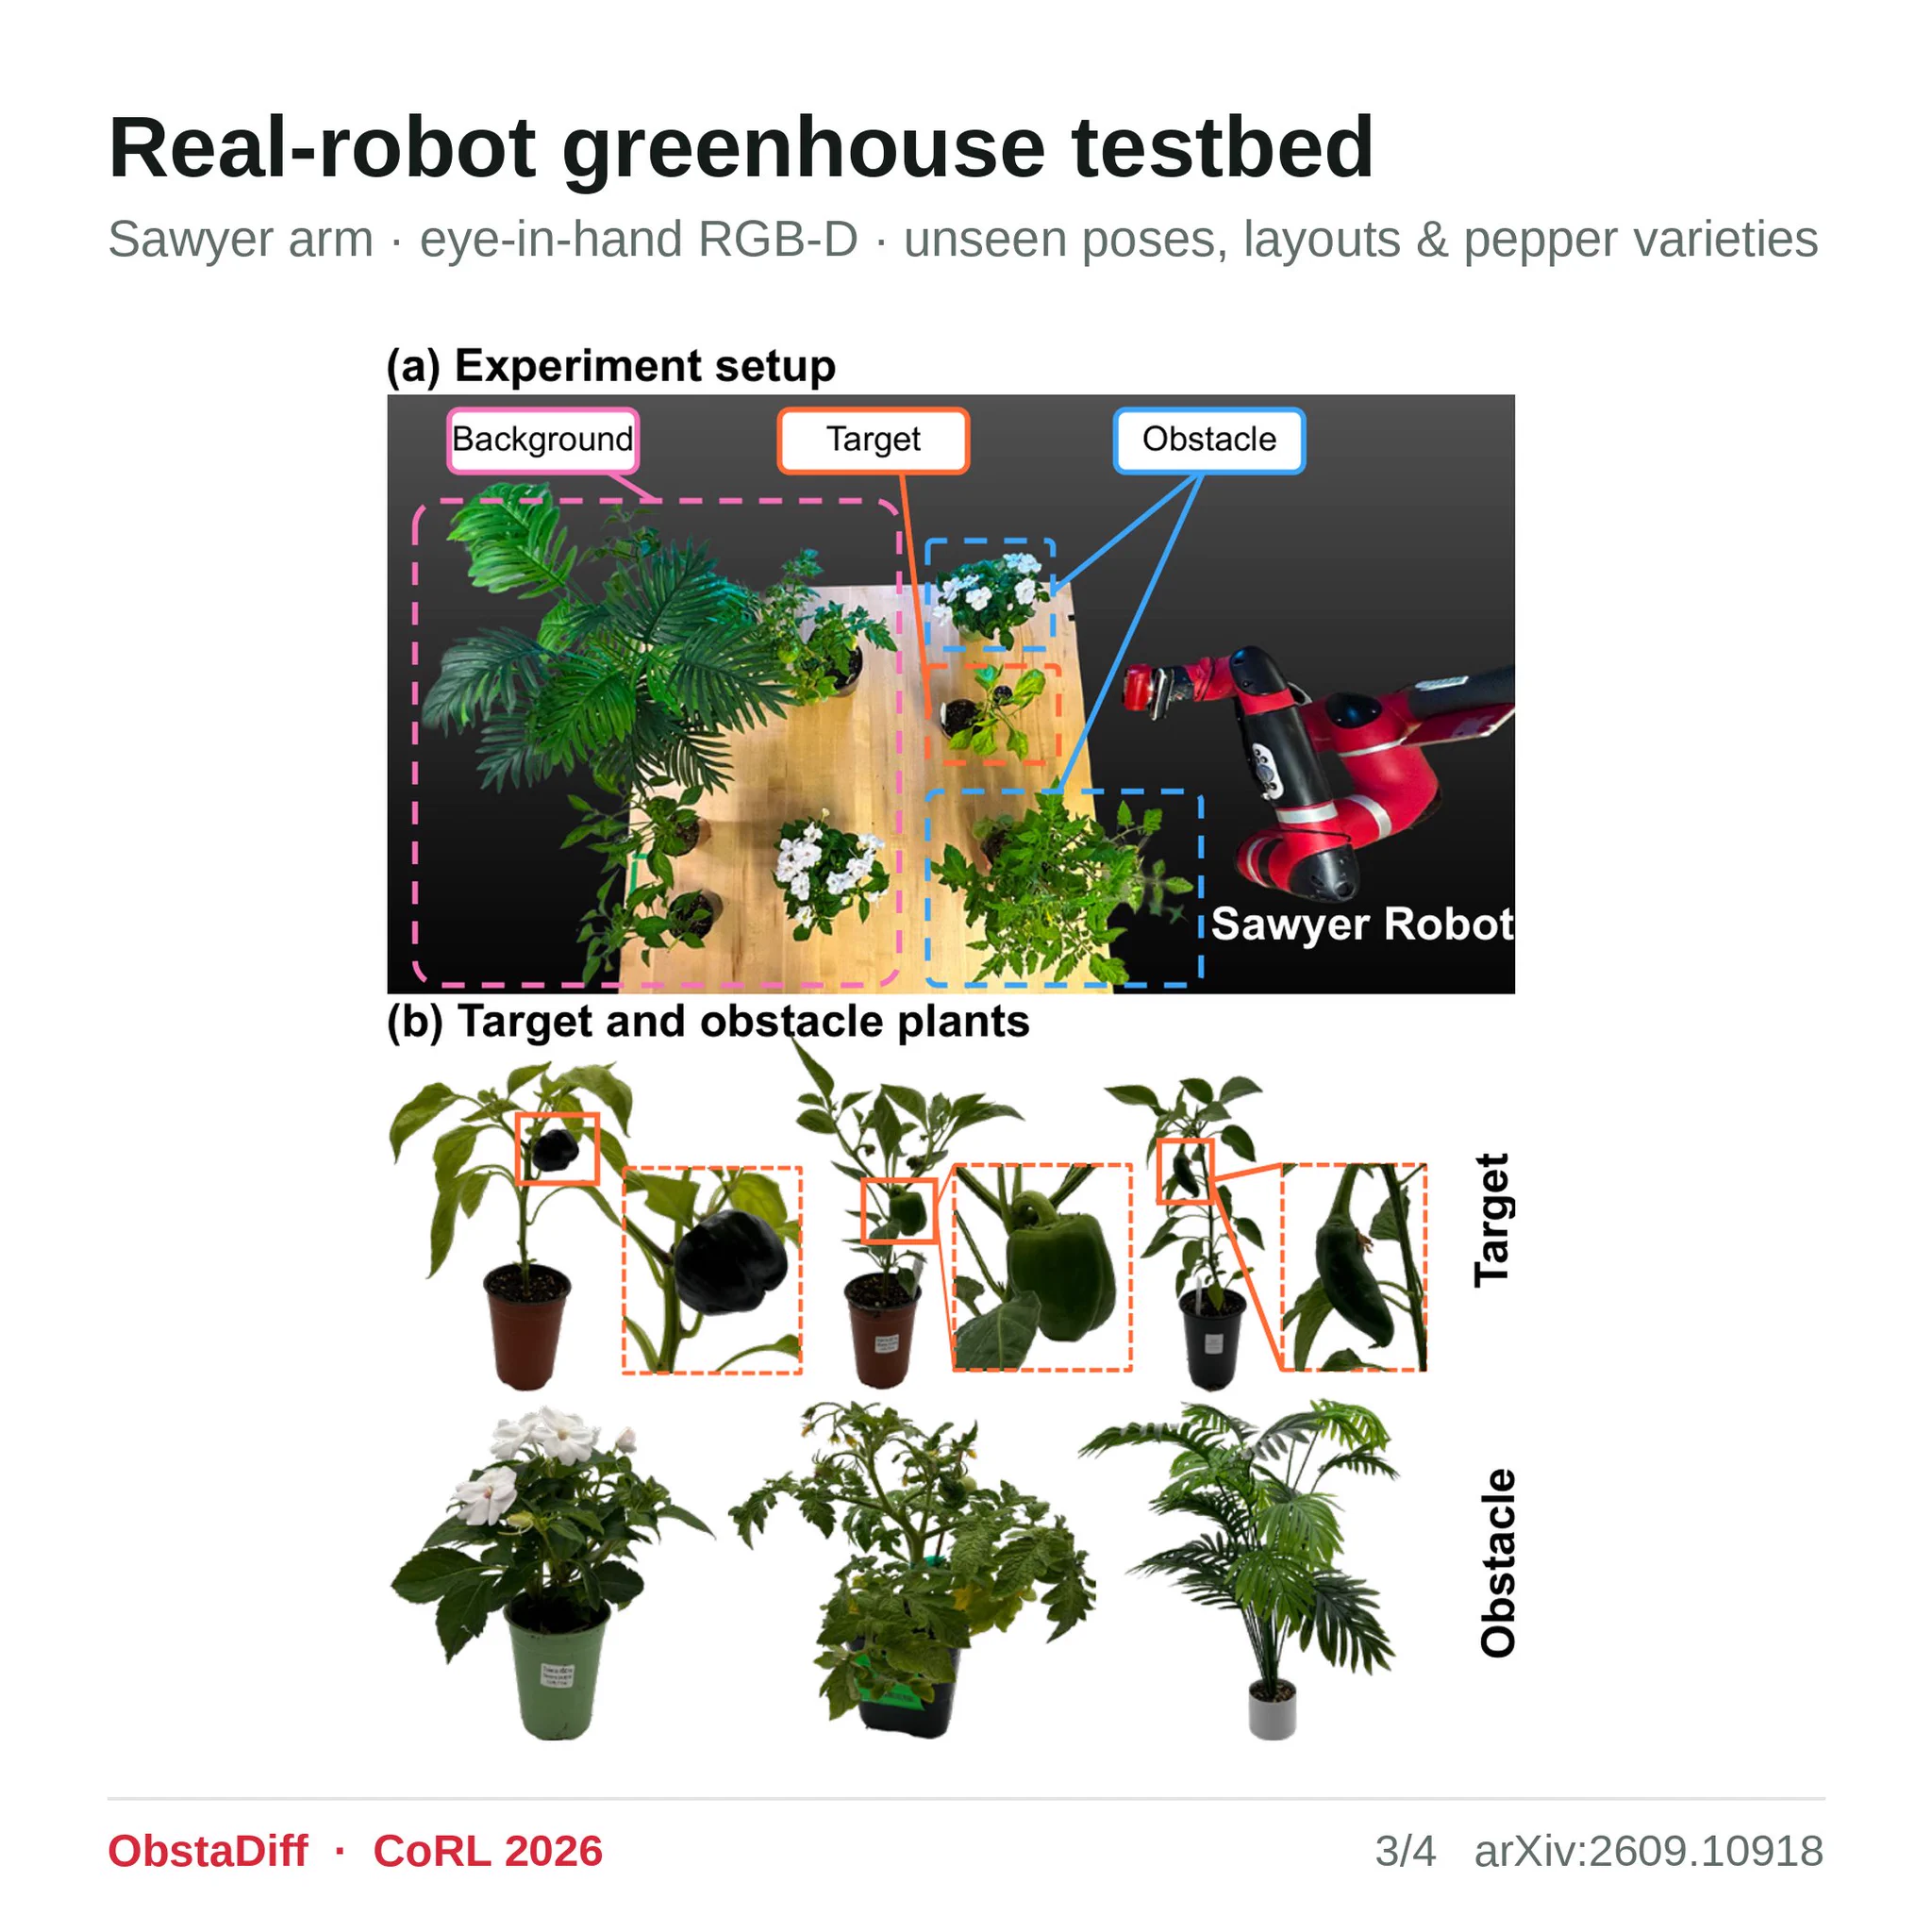
Approach: a learned policy guides the arm through the plants to a spot just in front of the target.
Interact: a recorded close-range motion finishes the job.
Up close, depth sensing gets unreliable, so replay is steadier.
#Robotics