

Dexterity,
engineered.
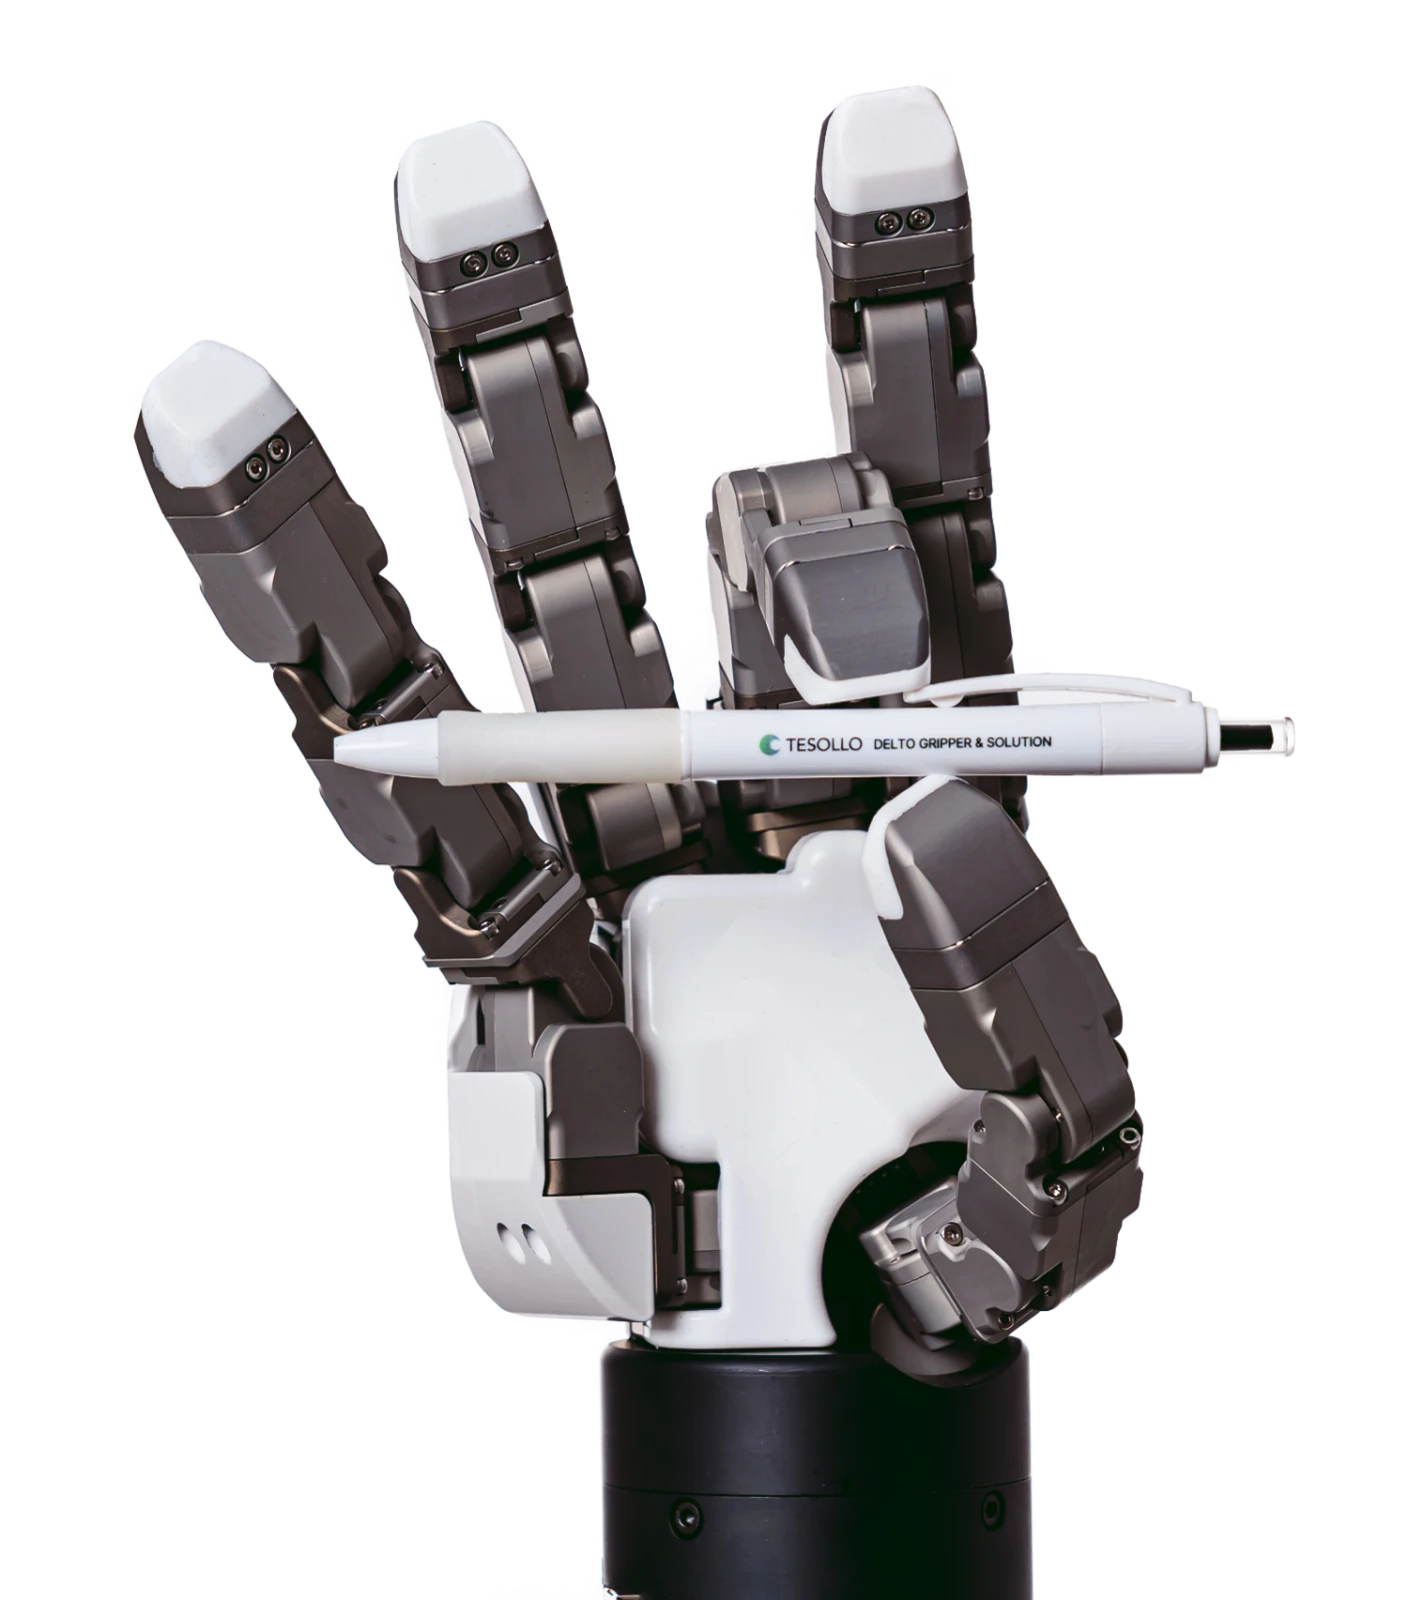
Tesollo develops a robotic hand platform built on proprietary integrated actuator technology, spanning dexterous multi-finger grippers and anthropomorphic robotic hands for Physical AI, humanoid robotics, and industrial automation.
From multi-finger grippers to five-fingered robotic hands.
Independent joint control, real-time feedback, and advanced algorithms enable stable grasping and precise manipulation across the lineup.
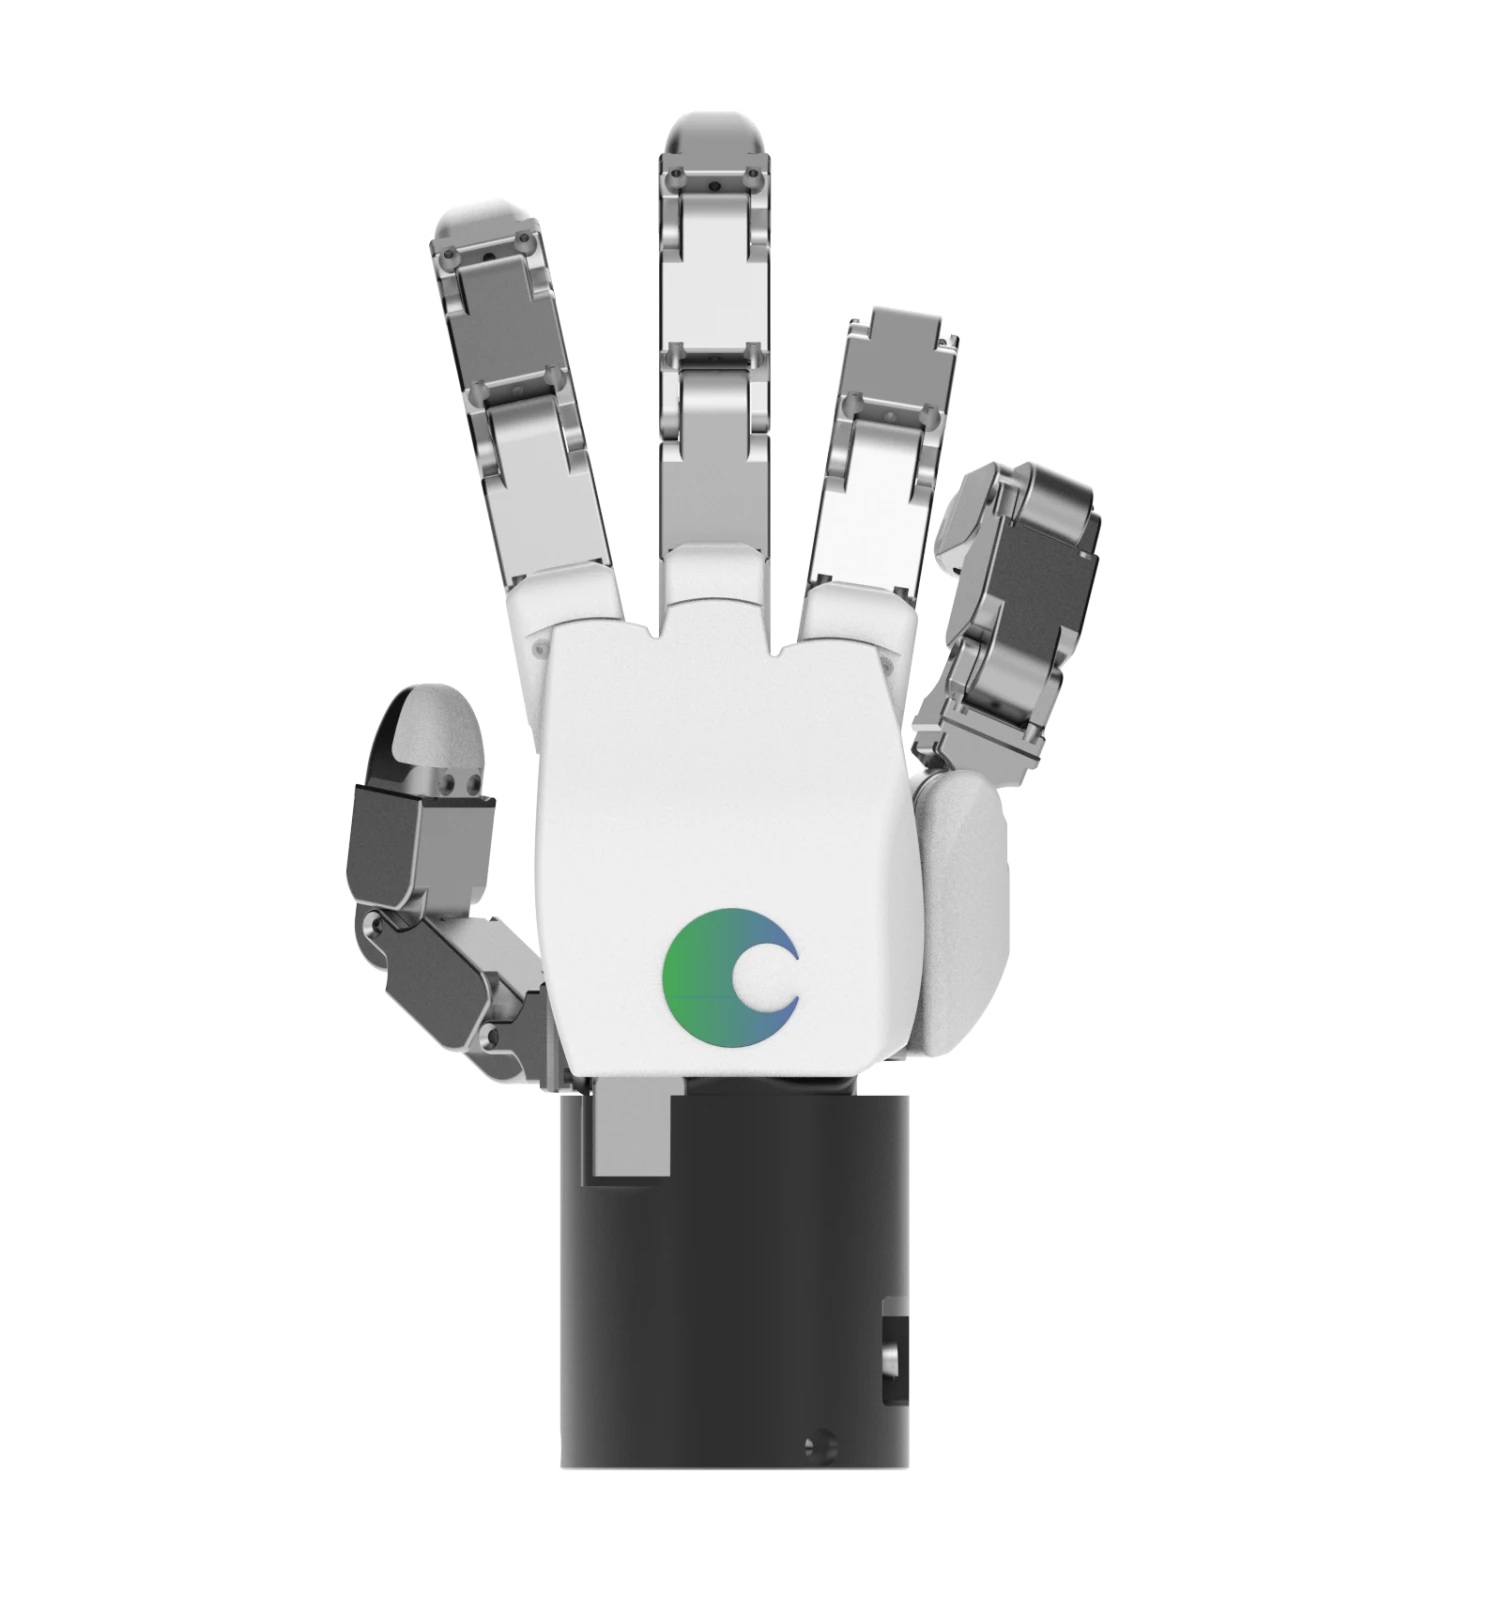
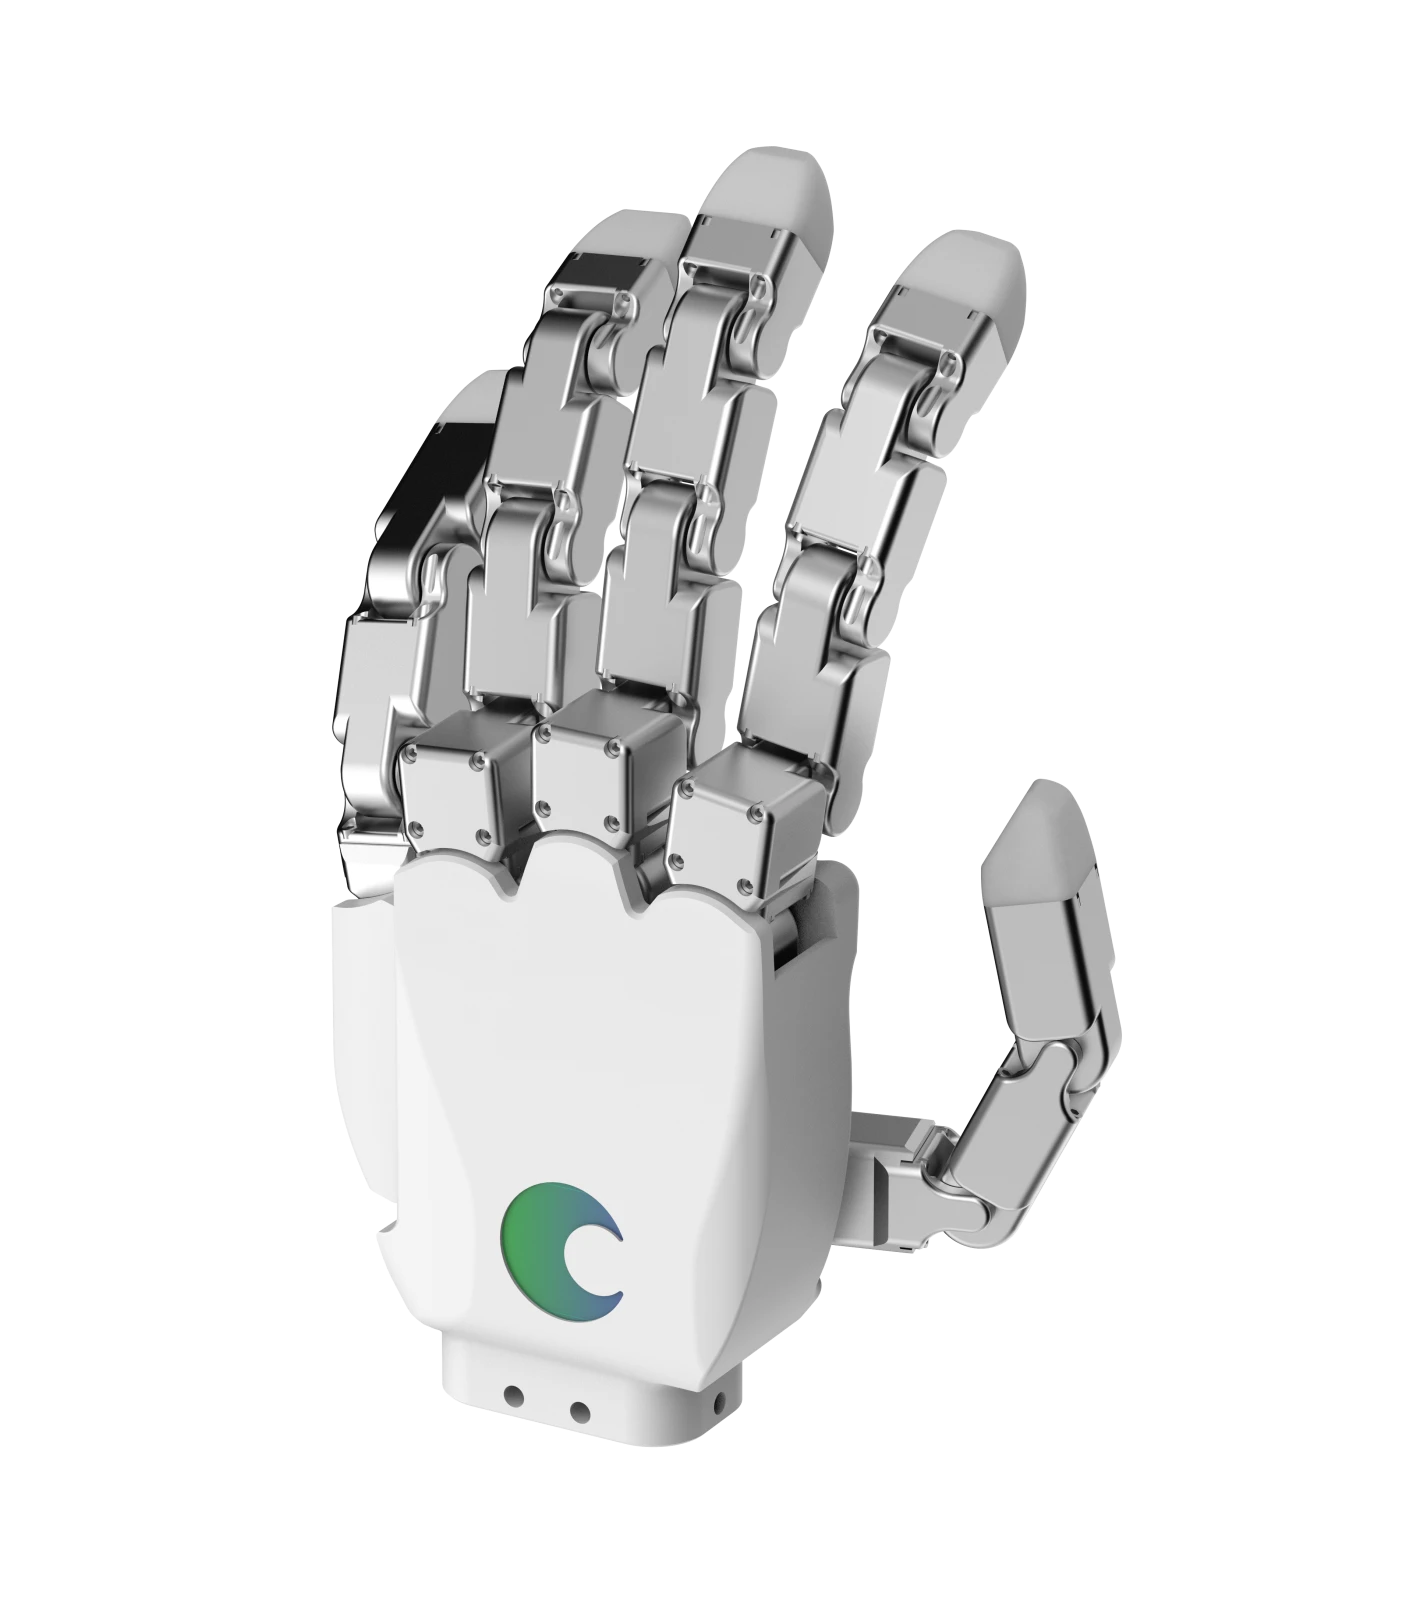
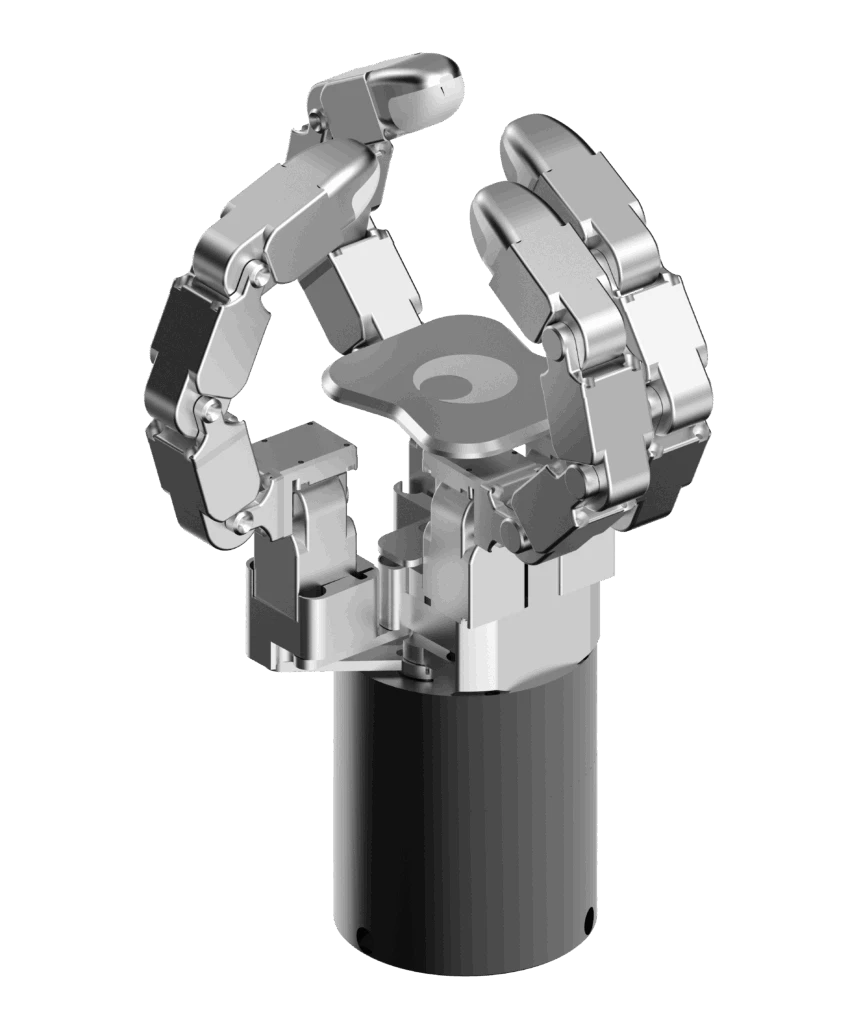
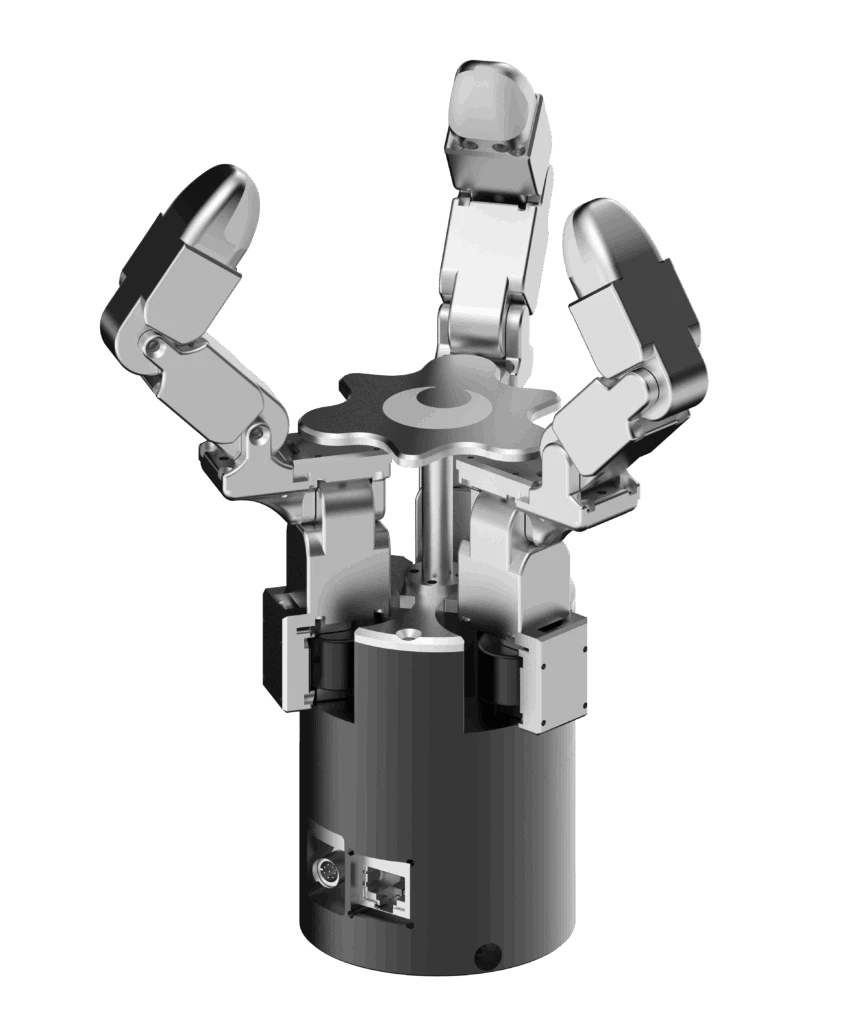
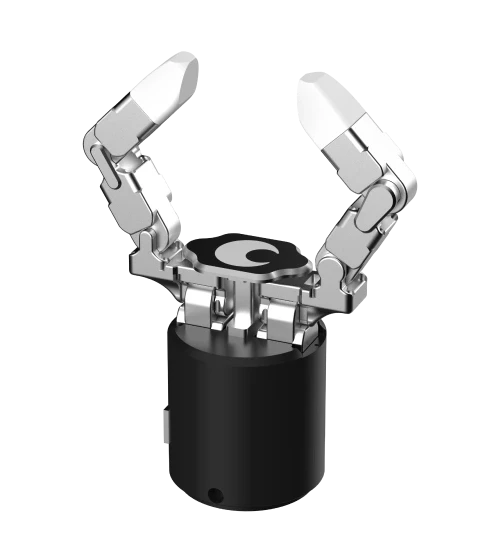


Dexterity built joint by joint.
From two-finger grippers to five-finger robotic hands, each product is designed with multiple articulated joints to adapt to diverse objects and tasks.
Each actuated joint is individually servo-controlled, enabling flexible finger postures and coordinated motion.
Position and current data from each joint provide the visibility needed for precise control, monitoring, and robotic learning.
Built-in control algorithms support stable grasping and advanced manipulation across a wide range of applications.


Ready to integrate a dexterous hand
into your platform?
Talk to our engineering team about gripper selection, integration, and lead times.
