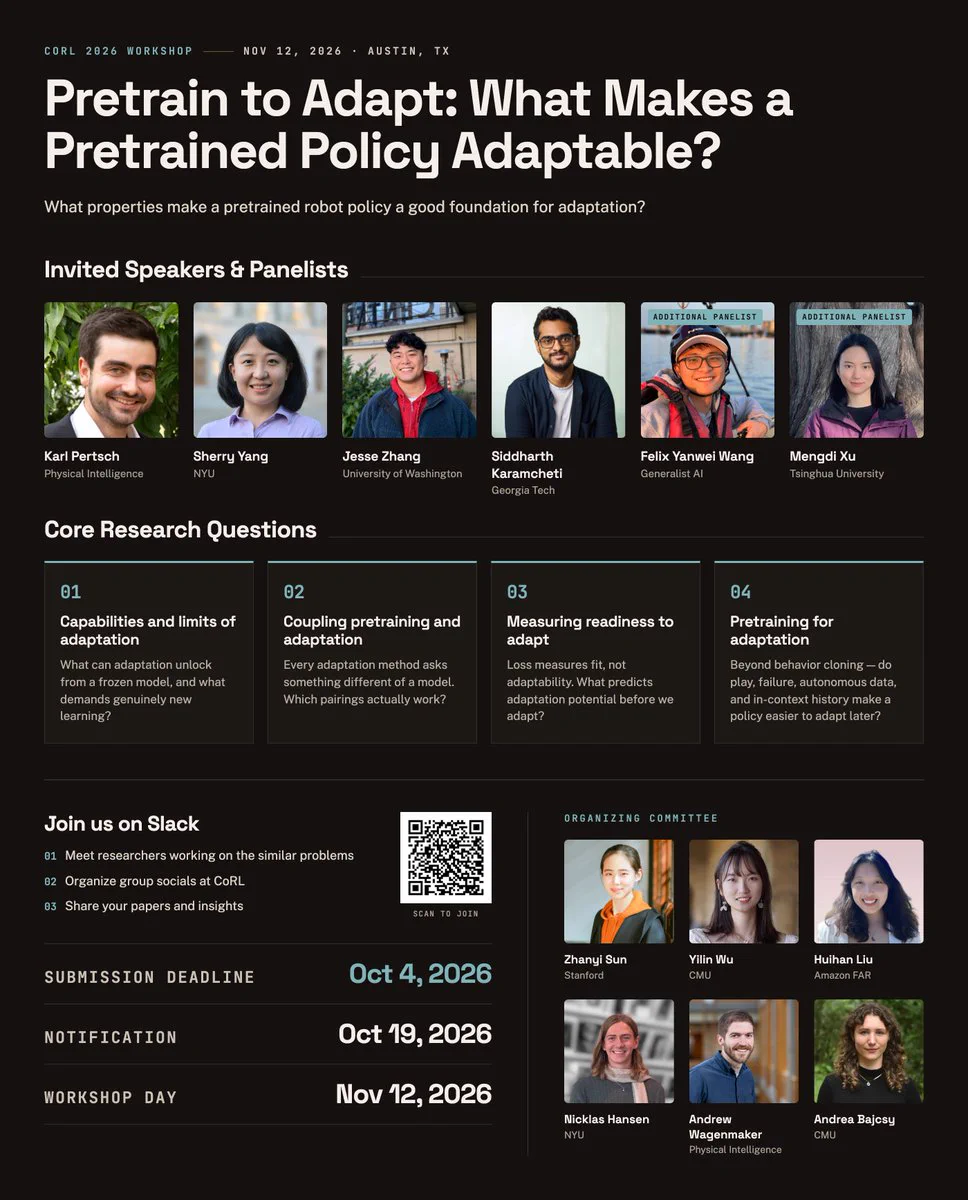
The strongest pretrained robot policy isn’t necessarily the easiest to adapt. How do pretraining and adaptation relate, and how can we pretrain policies that can be effectively adapted?
Come check out our workshop at CoRL 2026 to join the conversation!
corl2026-robotcl.github.io