Run OOMWOO on a Smartphone: ROS 2 on Android with Termux
OOMWOO will be able to use an old Android phone instead of a Raspberry Pi CM4/CM5. Step one: ROS 2 in Termux - options, instructions and measured proot overhead on a Pixel 7.
OOMWOO will be able to use an old Android phone instead of a Raspberry Pi CM4/CM5. Step one: ROS 2 in Termux - options, instructions and measured proot overhead on a Pixel 7.
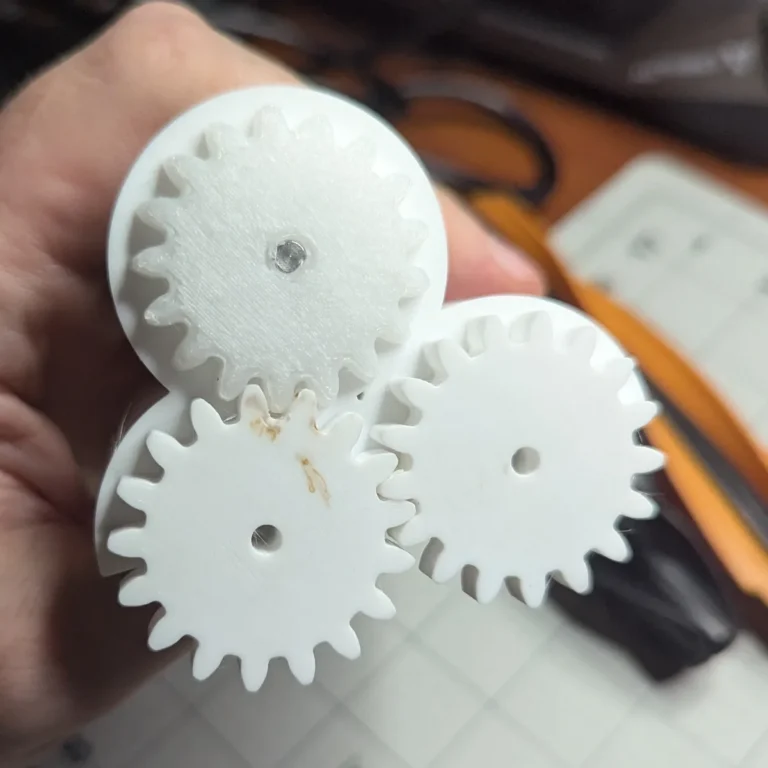
POM (Delrin) is the gear plastic in consumer robot vacuums, and notoriously hard to 3D print. Here is how I print it reliably: two sacrificial PETG layers first, then POM.
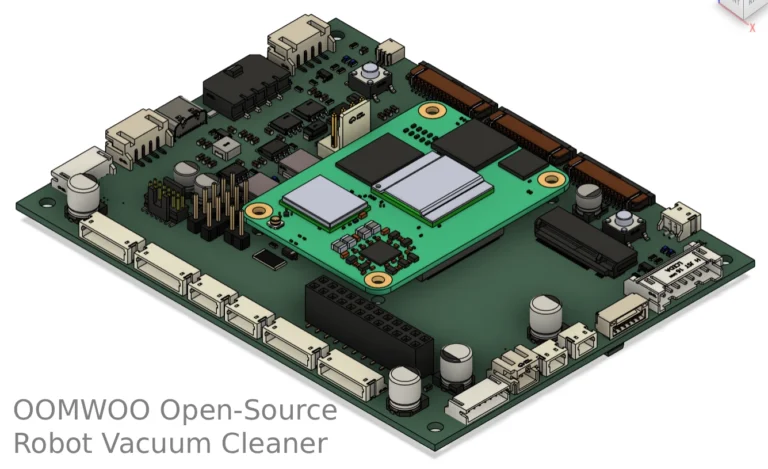
A module-by-module tour of the OOMWOO robot vacuum main board: compute, real-time control, power, fail-safe design, motors, sensors, audio and how we pick parts.
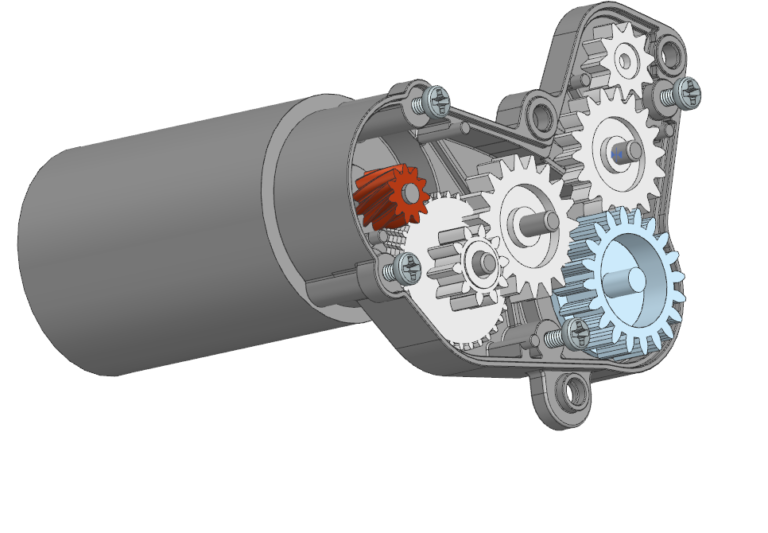
OOMWOO’s mechanical design is not drawn from a blank sheet. It starts by researching ready-made…
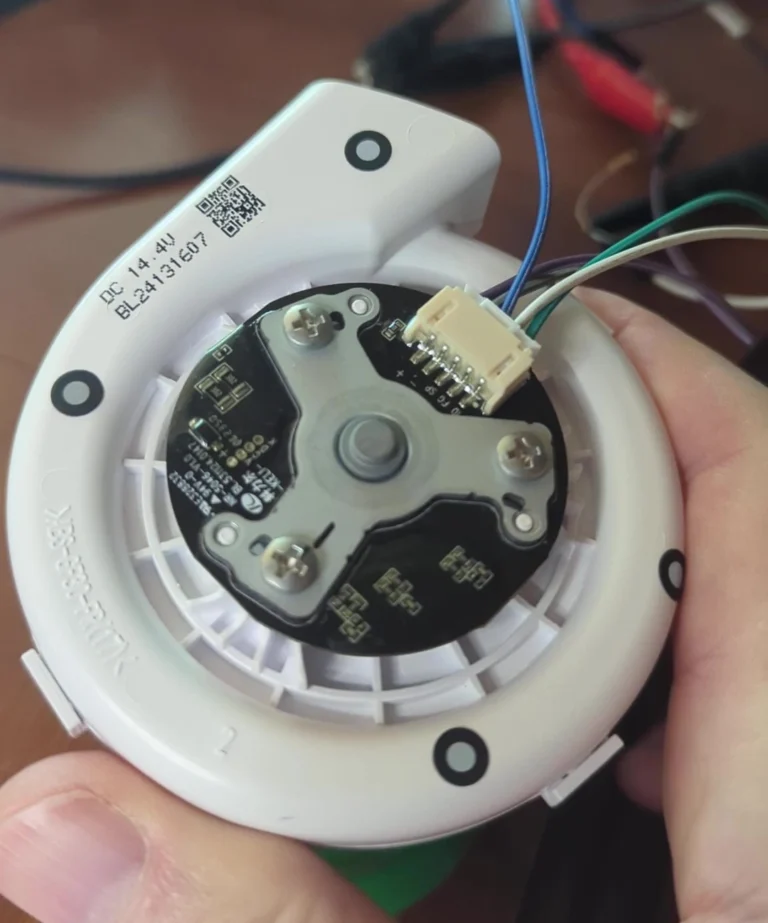
OOMWOO is built from sourced vacuum parts – Roborock drive wheels, off-the-shelf blower fans, iRobot…
Future home for OOMWOO open-source vacuum cleaner robot build instructions. Bring-up notes for the sourced…
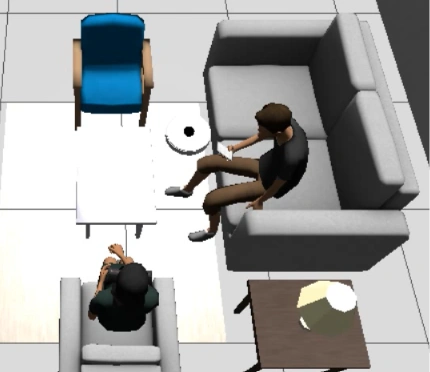
Here are issues we've ran into building OOMWOO open-source vacuum's cleaning, mapping and navigation - and our solutions.
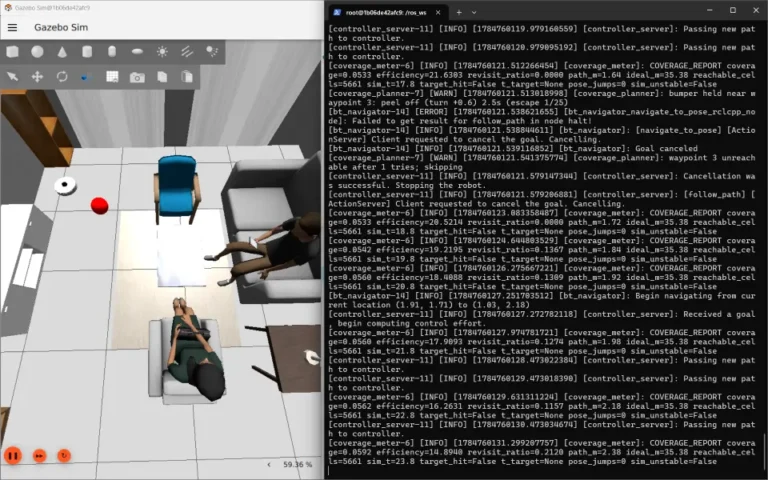
A concise, copy-paste quickstart for running the OOMWOO robot vacuum entirely headless (no display) —…
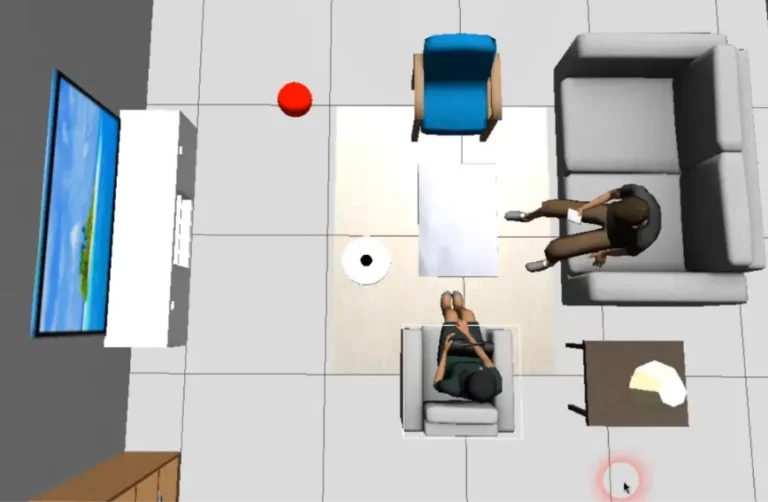
This is the “hello world” of developing for OOMWOO. It’s deliberately simple — a reactive…
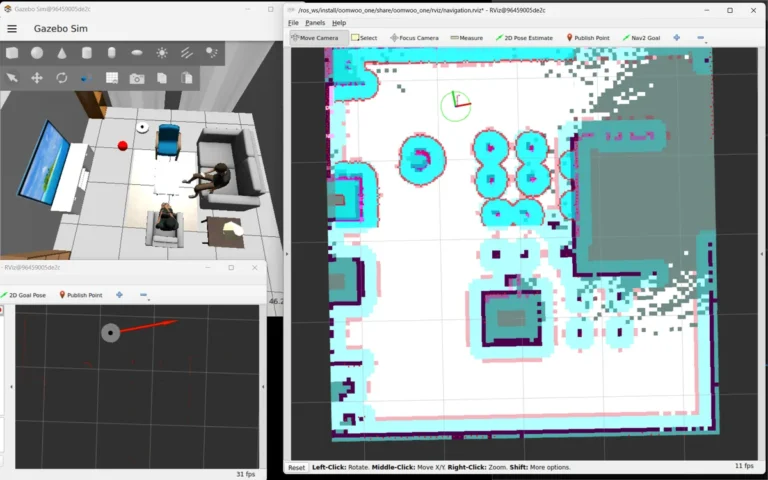
OOMWOO is an open-source robot vacuum you build yourself. oomwoo-one is the first model. This…
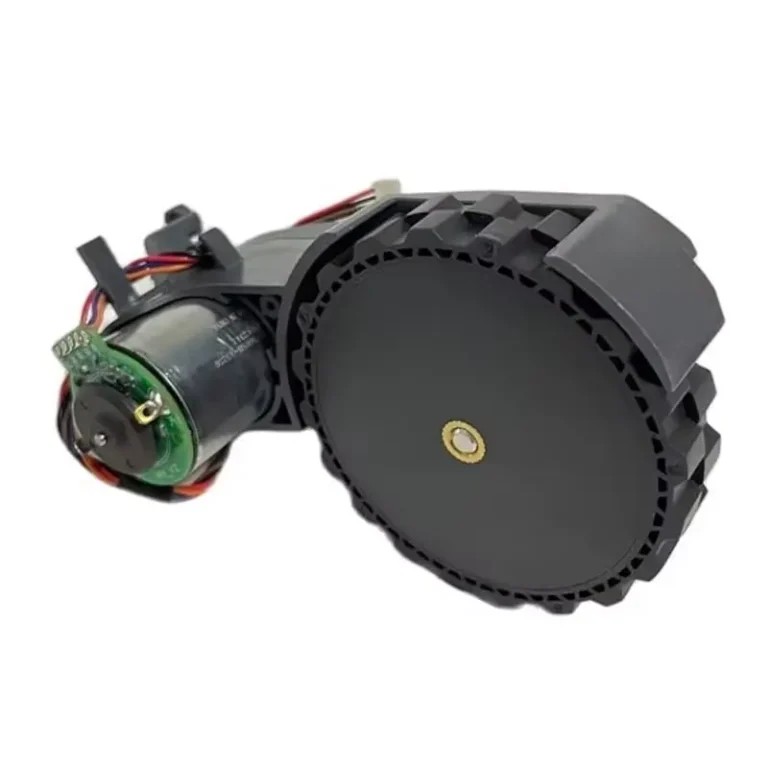
I started by drafting a list of parts and deciding which have to be sourced…
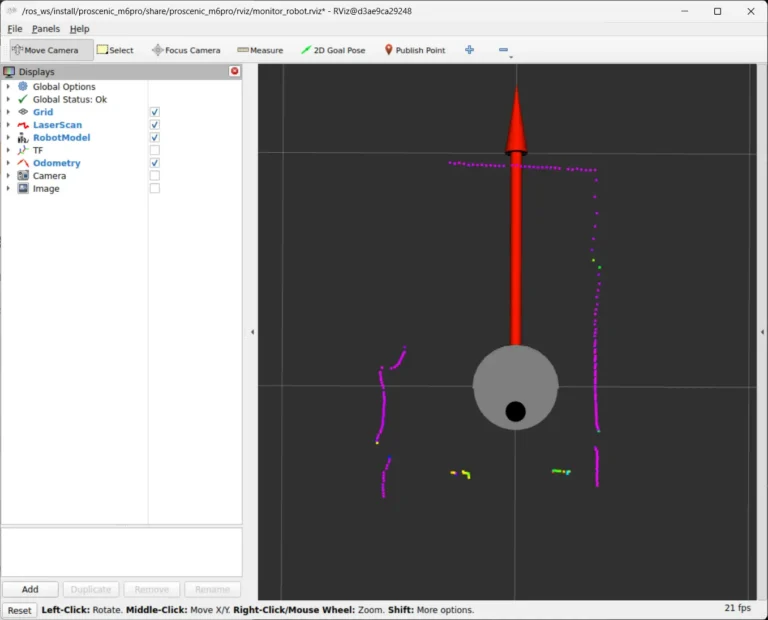
Tutorial Part 1 got SangamIO running on the vacuum, exposing its motors, wheel encoders, IMU…
Questions about a kit, an order, or your build? Drop us a note — we usually reply within a day.
